Articulated Surgical Arms
Optimizing spatial acuity, haptic flow, and operative homeostasis.


Structural Stability
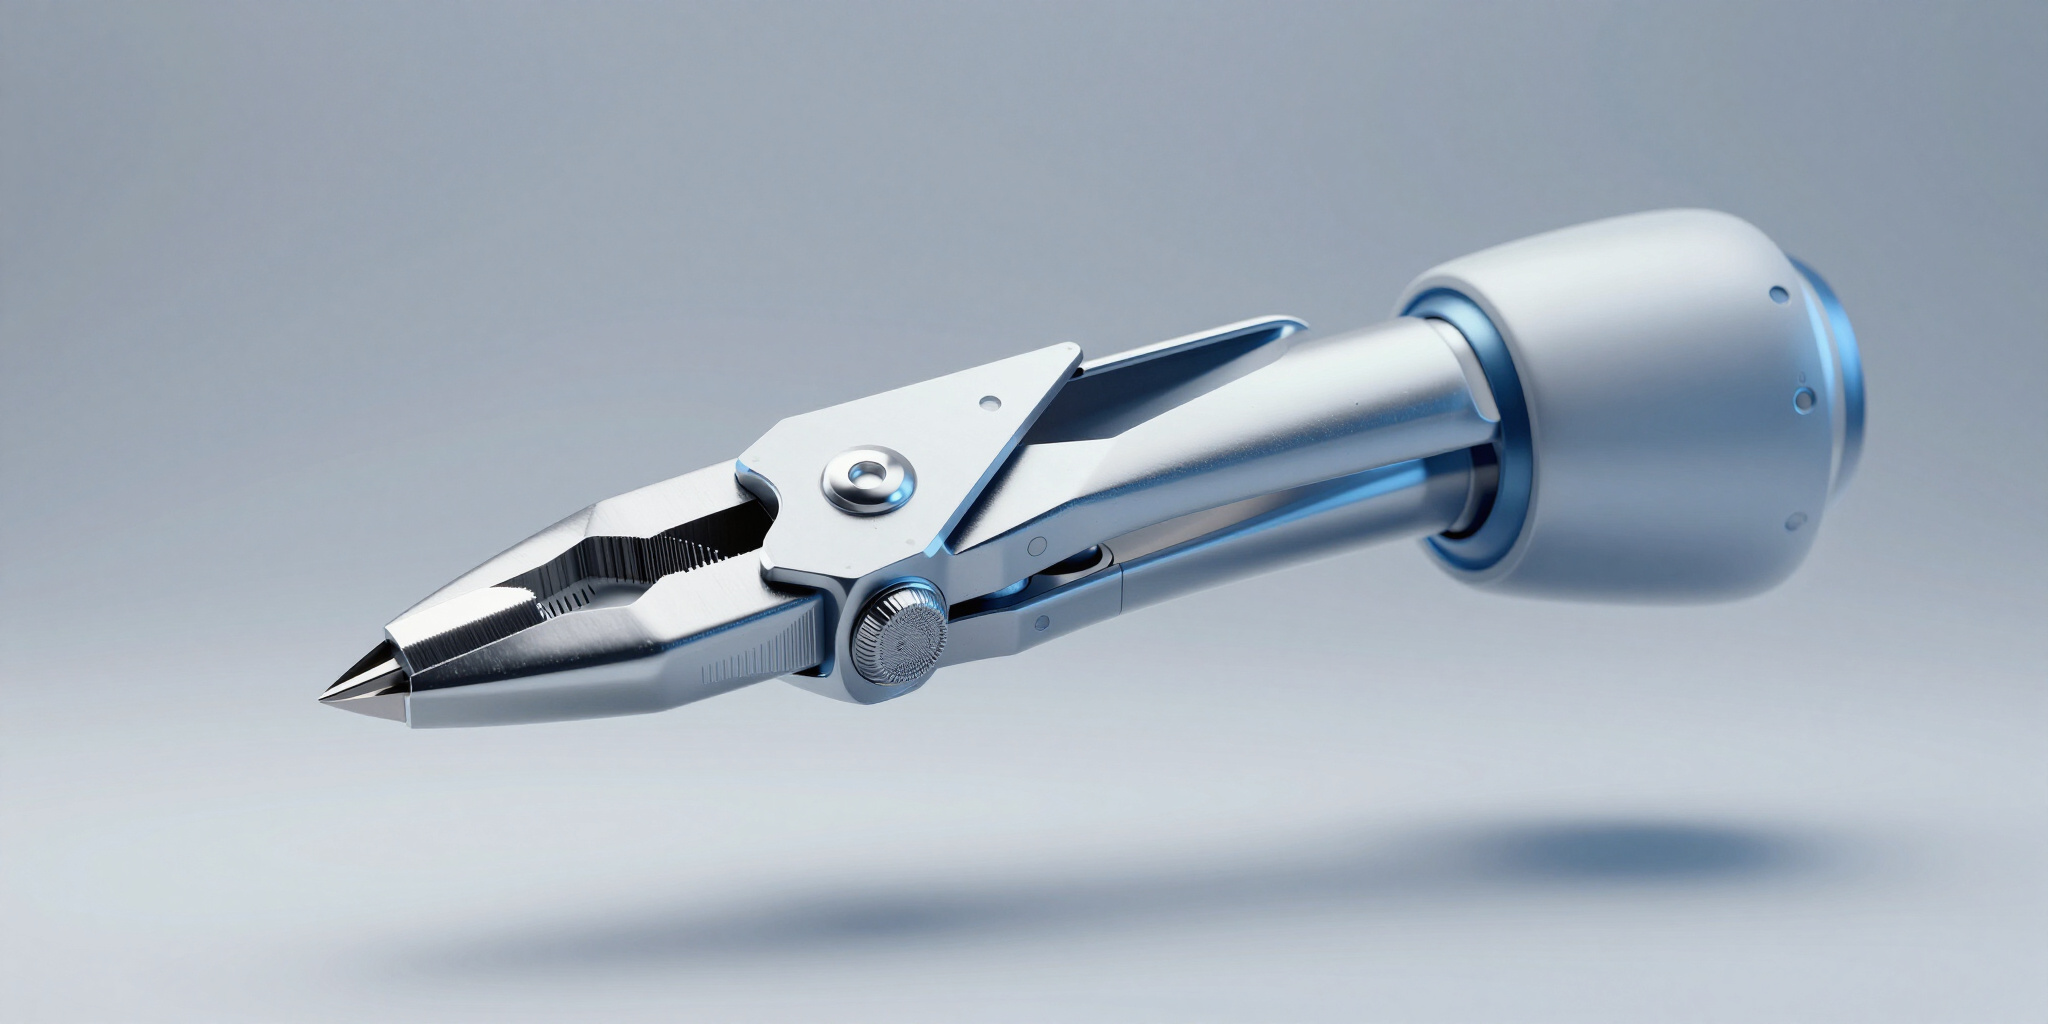
Integrating hyper-rigid scaffold geometries with multi-axis rotational degrees of freedom, the effector assembly replicates synarthrodial kinematics. Differential geometric constraints and low-friction interfacial linkages ensure absolute positional fidelity at maximal aperture.
Neural Feedback
Integrated transducer arrays utilize concurrent kinematic telemetry and haptic flux monitoring to modulate a high-frequency damping cycle. This algorithmic attenuation of physiological dissonance facilitates supra-human stabilization and non-linear predictive spatiality.
Dynamic Interface
Synarthrodial architectures facilitate operative navigation within hyper-constricted biological corridors where tissue fragility is maximum. By optimizing effector kinematics for deep-seated anomalies, the system bypasses macroscopic trauma to sustain absolute procedural integrity.
PLATFORM SPECIFICATIONS
Articulated Arms
Septa-axial carbon-composite arrays facilitate high-fidelity kinematic precision within restricted sub-millimeter topologies.
AI Navigation
Algorithmic spatial cognition via neural telemetry, projecting synchronized vascular schematics onto the ocular-interface.
Microsurgical Tools
Nano-scale 2.5mm effector arrays with localized ultrasonic cavitation and integrated piezoelectric strain-variance telemetry.
System Integration
Inter-nodal architecture utilizing modular convergence between effectors, neural logic, and instrumentation for post-human paradigms.

Ergonomic Precision
Synthesized for cybernetic cohesion, the interface architecture mitigates operator neuro-muscular depletion via haptic signal amplification. Cross-modal feedback loops calibrate to endogenous carpal kinematics.